

Robot Training for High Dexterity Manipulation Tasks
Mission
** Xikaku creates skilled robotic systems to support human workers. We solve the skilled labor shortage by enhancing worker productivity with collaborative robots. ** We record skilled human work with precise hand, finger and tactile sensing and use it to train robots for a specific task.
See the latest and greatest in our blog!
Technology
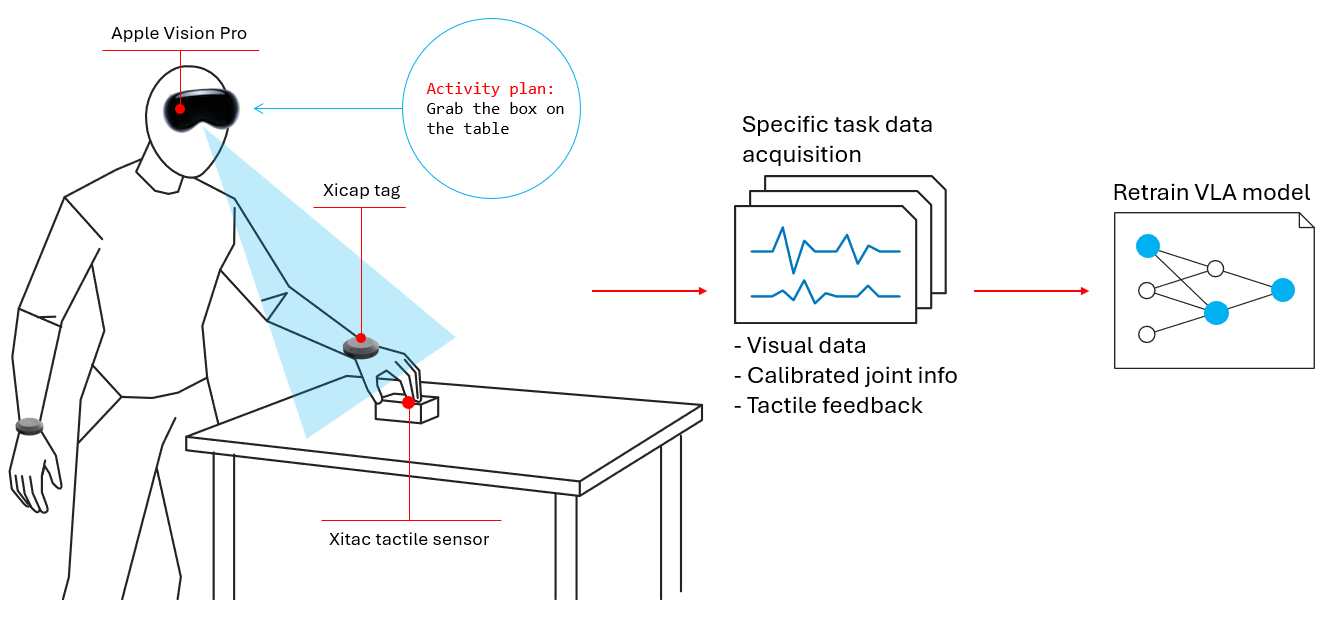
A skilled worker does the task while we record what they see, how their wrist and fingers move and how hard they press. That data is used to fine-tune the action part of an existing world-action model. We don’t train from scratch; the base model already knows how hands and objects move.
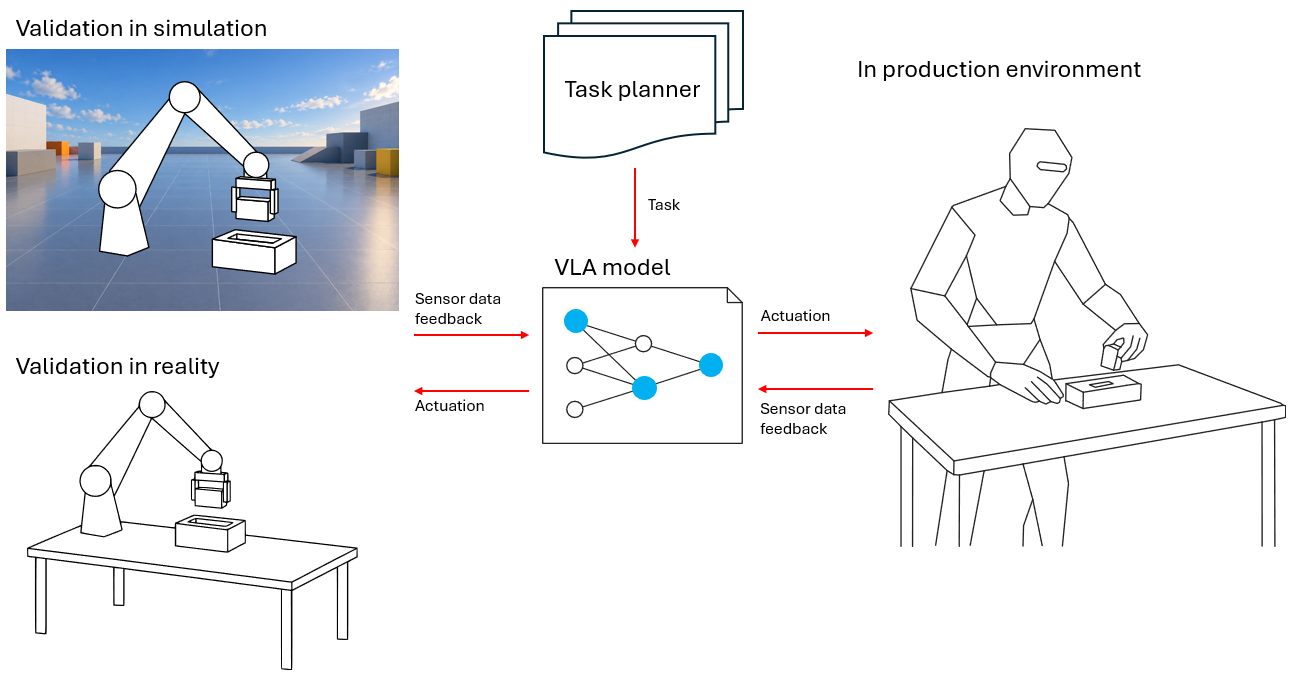
Every model is validated in simulation and on a real robot before it goes to the shop floor. There the robot works next to people, not instead of them.
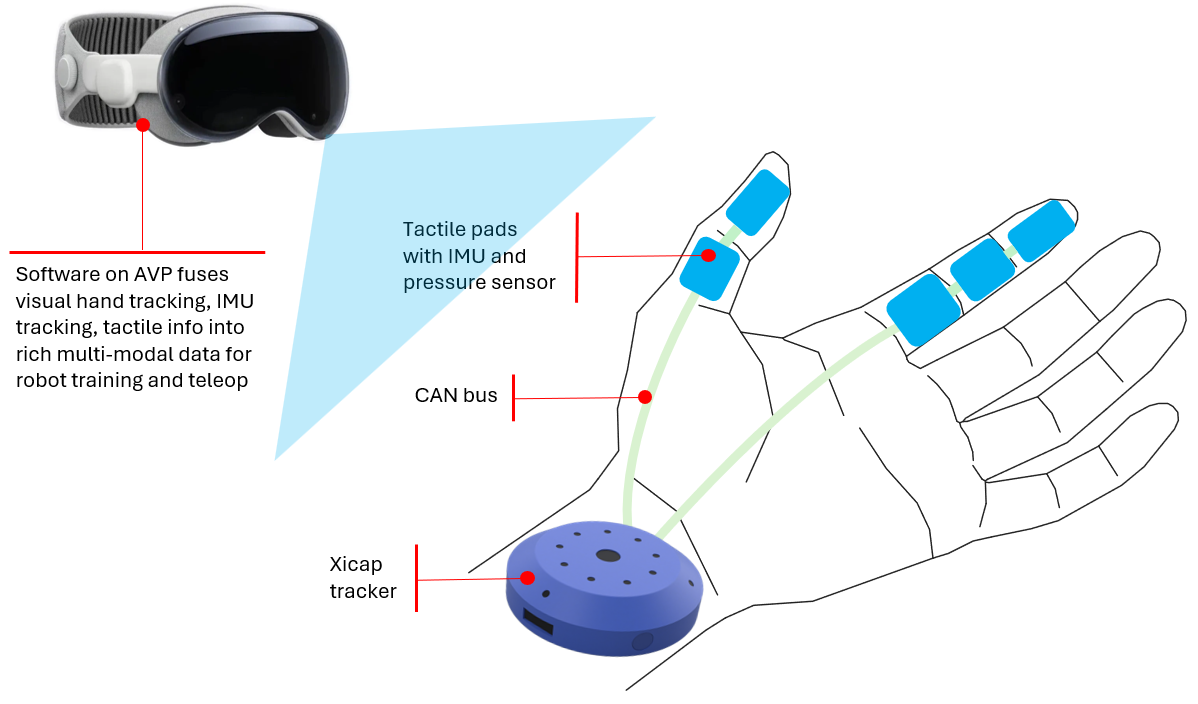
The XiCAP tracker measures wrist pose. Fingertip pads carry an IMU and a pressure sensor each. The Vision Pro fuses its own hand tracking with the IMU and tactile data: position without drift, motion without occlusion, and the force a camera can’t see.
Built On Our Sensors
The XiCAP capture hardware is built on our LPMS inertial sensor line, which remains available as a standalone product. The Xikaku LPMS product line covers a full range of inertial measurement units (IMUs) - from wireless sensors to rugged IP67 navigation-grade units with integrated GNSS.
 LPMS-B2 Series - 3D IMU / AHRS · Wireless Bluetooth 2.1 / BLE · Internal flash memory recording
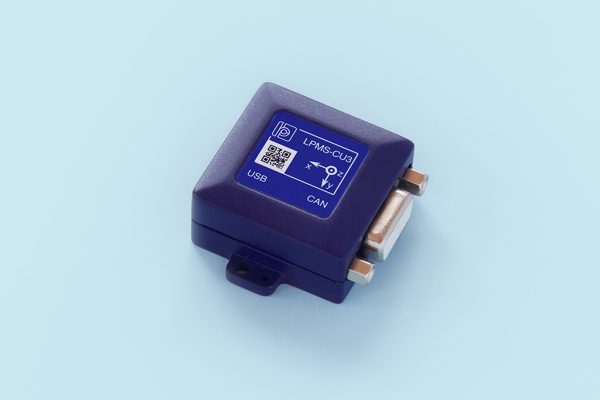 LPMS-U3 Series - 3D IMU / AHRS · USB, CAN Bus, RS232 or TTL · Compact plastic enclosure
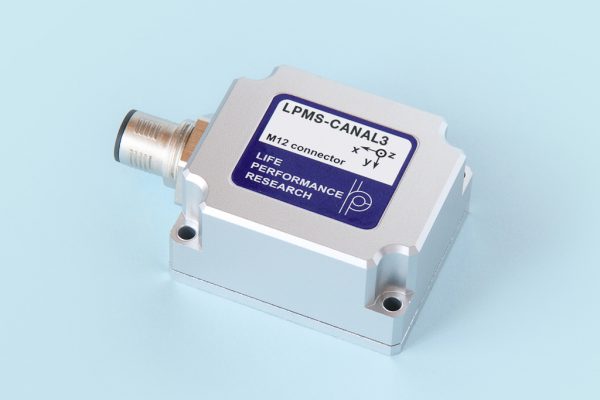 LPMS-AL3 Series - 3D IMU / AHRS · IP67 waterproof housing · CAN, RS232, TTL or USB
 LPMS-IG1 Series - 9-axis IMU / AHRS · Dual gyroscopes for range flexibility · USB / CAN / RS232 / RS485
 LPMS-IG1P Series - 9-axis IMU / AHRS · Integrated GPS and RTK-GPS · Dead-reckoning for localization
 LPMS-IG1W Series - 9-axis IMU / AHRS · Wi-Fi for industrial IoT · Dual gyroscopes, IP67
See the full Sensors page for complete specifications and datasheets.
Real-time Sensor Fusion
FusionHub does the IMU-optical fusion inside the capture system.
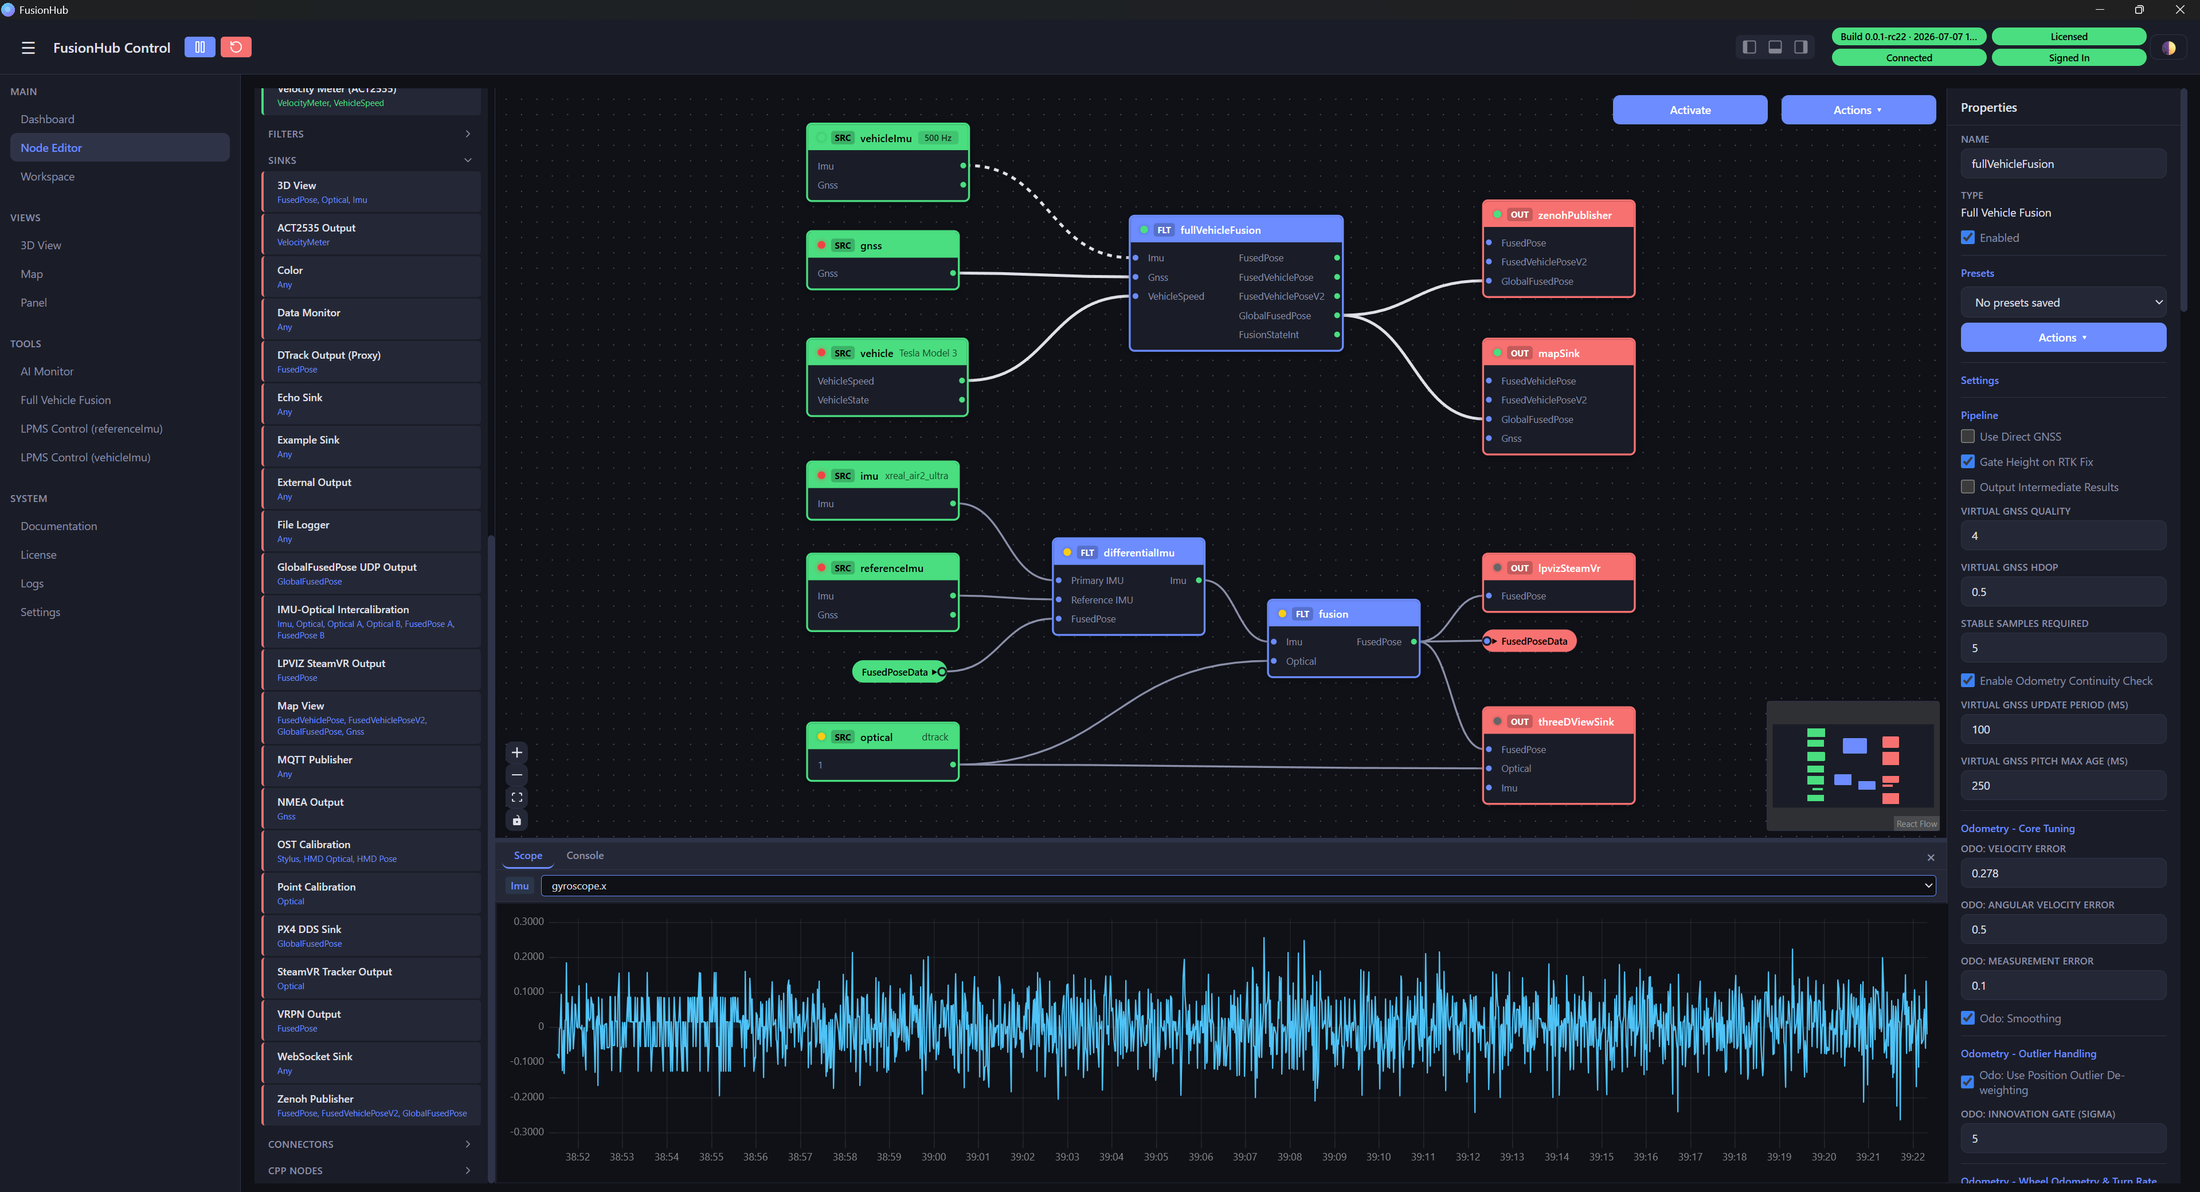
FusionHub is Xikaku’s sensor-fusion engine. It connects to IMUs, GNSS/RTK receivers, wheel odometry, and optical trackers, fuses them through a collection of highly optimized real-time filters, and outputs continuous, low-latency pose, motion and navigation data.
One engine covers ground vehicles and AGVs, aerial platforms, vessels, mocap stages and AR/VR headsets. It runs as a single native binary on Windows, Mac and Linux, on the desktop or headless at the edge, and embeds into your own software over a plugin API, TCP/IP or UDP.
Instead of hand-wiring GPS drivers, IMU filters, odometry math and protocol converters, you get one configurable engine:
- Standard sensors and protocols - first-party integrations, no custom drivers to write.
- Field-tested fusion - IMU-optical, GNSS-IMU, odometry-IMU, differential IMU, COG-referenced heading and more.
- Ready-made outputs - ROS 2, NMEA, MQTT, VRPN, DDS and WebSocket.
- Deploy anywhere - Windows, Mac or Linux, GUI or headless, embeddable via C FFI, licensed per feature.
See the full FusionHub page for architecture details, supported sensors, and deployment examples.
Our Story
Xikaku is an American company headquartered in Venice, California, and the US companion of LP-Research, our Tokyo-founded sensor and sensor-fusion R&D group. Together we turn two decades of motion-sensing research into products that ship worldwide across automotive, aerospace, robotics, industrial, and AR/VR.
Read the full Our story - from a Tokyo robotics lab to LP-Research, LPVR, and Xikaku in Venice, California.
Contact
Xikaku, Inc.
4223 Glencoe Ave, Suite C215
Marina Del Rey, CA 90292
show email