

LPMS-NAV3: 6-Axis Navigation IMU with RS232, RS485, RS422, TTL or CAN
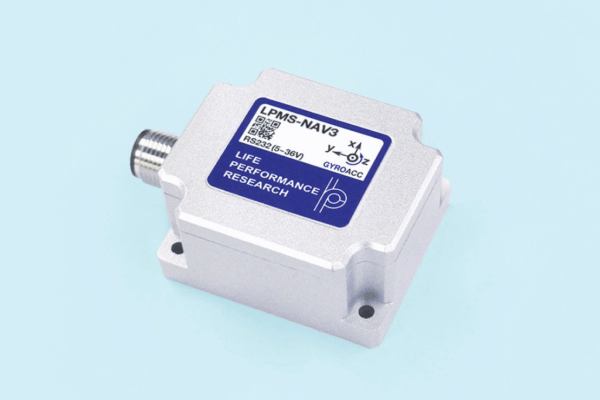
The LPMS-NAV3 is a 6-axis high-performance IMU with RS232, TTL, RS422, and RS485 communication interfaces. A 3-axis accelerometer and gyroscope are paired with a high-accuracy single-axis gyroscope for precise heading calculations, in a rugged IP67 aluminum enclosure.
Key features
- 6-axis configuration with dual gyroscope design
- TTL, RS232, RS422, and RS485 interfaces
- 500 Hz internal sampling and maximum output rate
- Raw data, Euler angles, quaternion, linear acceleration, and temperature output
- IP67 water-resistant aluminum housing
- Operating range −20 to +80 °C (extended to −40 °C available)
- Compact dimensions: 50 × 42 × 25 mm
- Low power consumption (0.072 W typical)
- Configurable via LPMS-Control2
Variants
- LPMS-NAV3-TTL - TTL / UART (LPBUS)
- LPMS-NAV3-RS232 - RS232 (LPBUS)
- LPMS-NAV3-RS485 - RS485 (LPBUS / MODBUS)
- LPMS-NAV3-RS422 - RS422 (LPBUS)
- LPMS-NAV3-CAN - CAN + TTL (CANopen / Sequential CAN)
All variants share the same 6-axis high-accuracy heading IMU, 500 Hz sampling, M12 connector, and IP67 housing - choose by host-side interface.
Specifications
| Parameter | Value |
|---|---|
| Orientation range | Roll: ±180°, Pitch: ±90°, Yaw: ±180° |
| Resolution | 0.01° |
| Accelerometer | 3-axis, ±2 / ±4 / ±8 / ±16 g, 16-bit |
| Gyroscope (X, Y) | ±125 / ±250 / ±500 / ±1000 / ±2000 / ±4000 °/s |
| Gyroscope (Z, heading) | ±400 °/s, 24-bit |
| Power | 5-18 V DC |
| Weight | 106.8 g (±4 g) |
| Connector | M12 |
Applications
Automotive, mobile robotics, and AGV navigation requiring accurate heading information.